 Quick preview
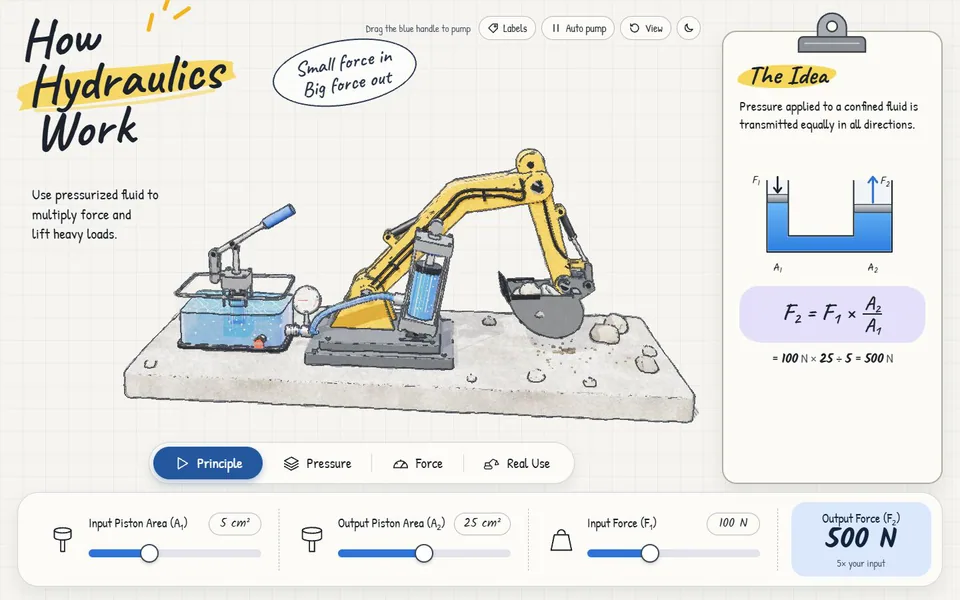
Adjust the pistons and input force to lift a tiny excavator arm.
By The Bugged Dev
Experiments · Creative references
Move a robot hand and watch its joints cooperate to reach a target.
By Unconfirmed
Open experience ↗Opens on the creator’s website01 / GET STARTED
Drag the hand toward the green target on the original page.
02 / ABOUT THE CREATION
Small challenges make inverse kinematics more intuitive.
03 / MORE TO KNOW
This educational model is not a controller for a physical robot.
Quick preview Adjust the pistons and input force to lift a tiny excavator arm.
 Quick preview
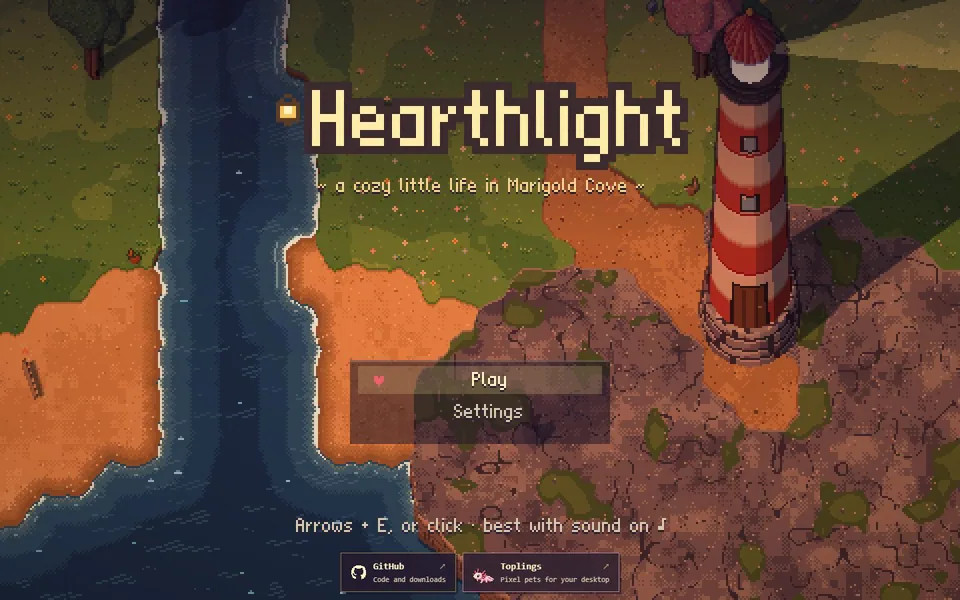
Step into a cozy pixel-art seaside village and begin an adventure.
 Quick preview
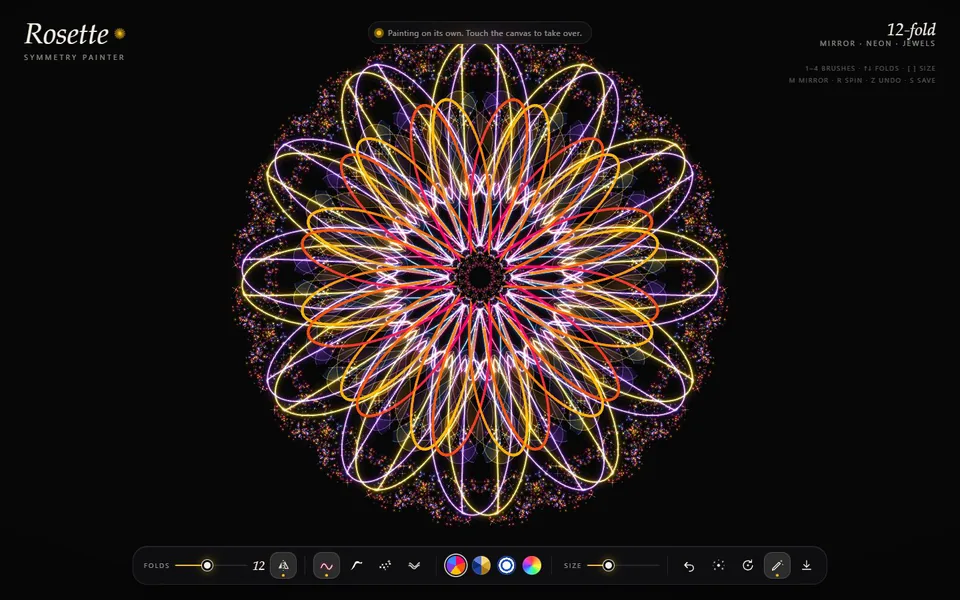
Draw a stroke and watch it bloom into a colorful symmetrical pattern.